
I’m a Ph.D. student at the Robotics Institute, Carnegie Mellon University. I work with Dr. Matthew Travers, in The Matt Lab and Biorobotics lab. In Summer 2026, I was a Robotics Research Intern at Multiply Labs working with Dr. Jiuguang Wang on uncertainty-aware manipulation tasks. I was awarded the Uber Presidential Fellowship at the Robotics Institute, Carnegie Mellon University for the 2026–2027 academic year.
My current research focuses on mainly two things:
- Interaction-aware Motion Planning: Developing algorithms that reason about robot-environment interactions to navigate realistic complex environments
- Uncertainty-aware Active Perception: Developing strategies for robots to actively reduce environmental uncertainty through targeted sensing actions
Email CV Google Scholar Github
I also completed my Masters in Robotics from Carnegie Mellon University. Before that, I worked under Prof. Rajasekar Mohan in the Microsoft Innovation Lab at PES University, Bengaluru and graduated with a Bachelors degree in Electronics and Communication Engineering.
I was also running a YouTube Channel, All About Robots where I used to create simple tutorial videos on Robotics and Robot Building (currently inactive). My other hobbies include cooking, playing FPS games, astronomy, video editing and mobile photography.
News & Updates
-
September 25, 2026NEW Honored to be awarded the Uber Presidential Fellowship at the Robotics Institute, Carnegie Mellon University for AY 2026–2027!
-
September 27, 2026NEW Co-organizing the IROS 2026 workshop on “Rethinking Uncertainty for Modern Robotics Paradigms” in Pittsburgh, PA!
-
May 18, 2026Interning at Multiply Labs for Summer 2026, working with Dr. Jiuguang Wang on uncertainty-aware manipulation tasks.
-
February 1, 2026
-
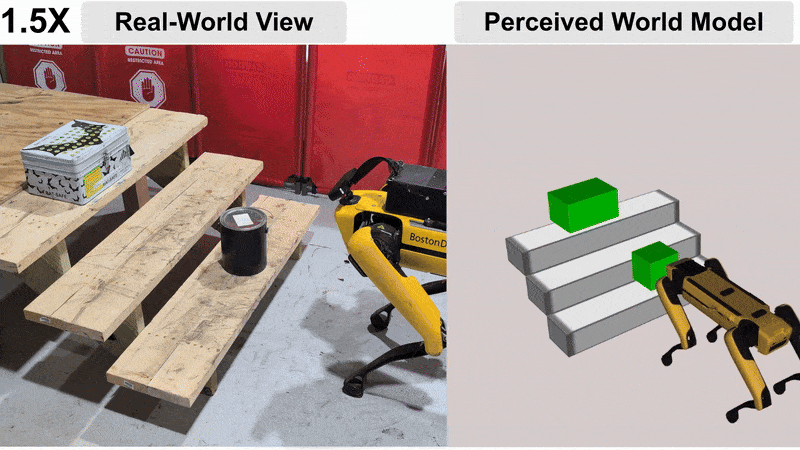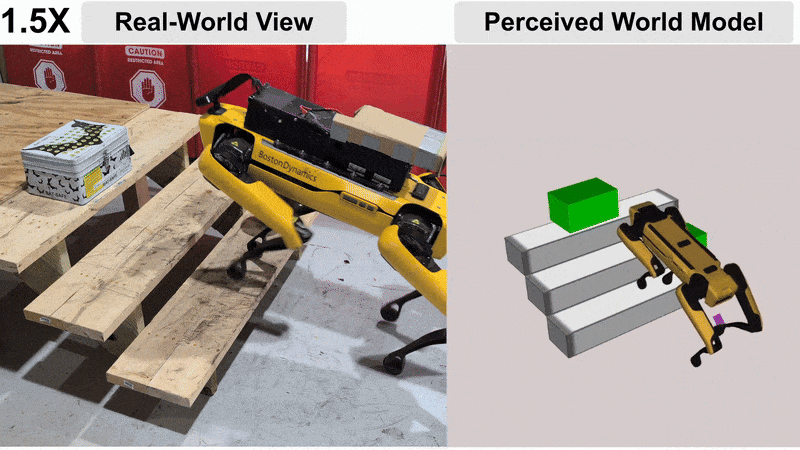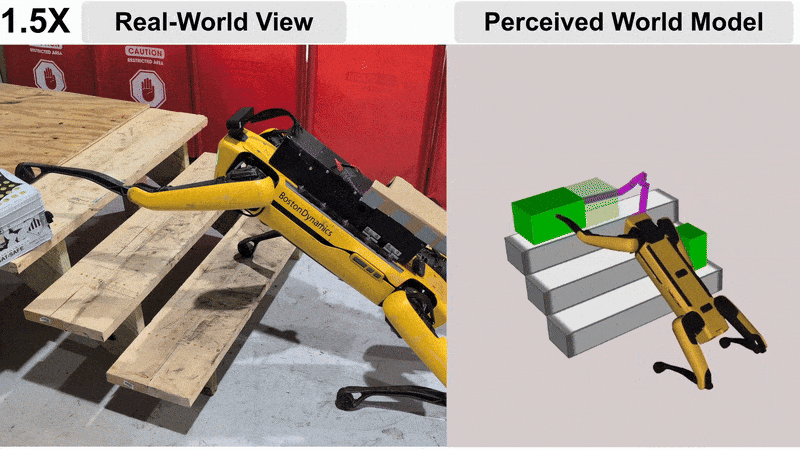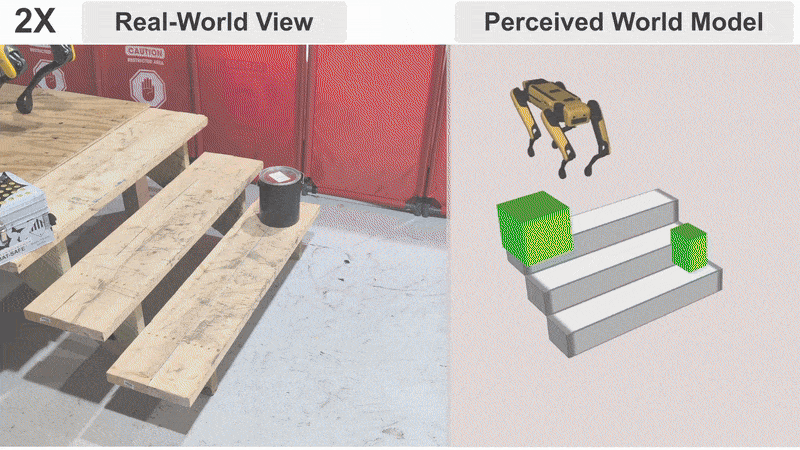
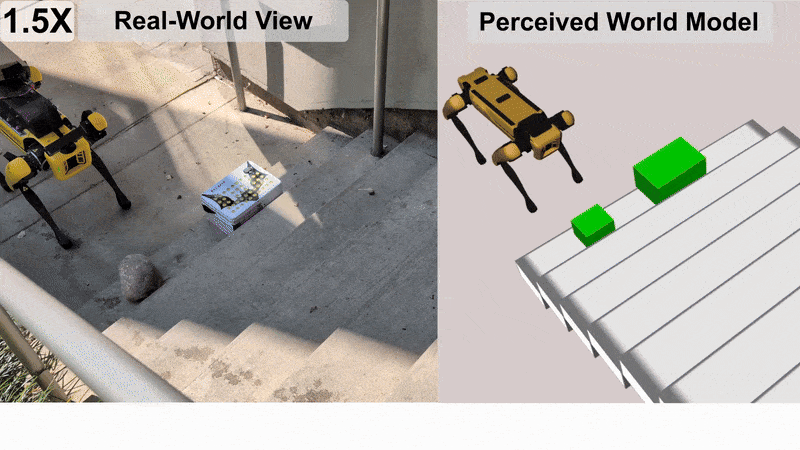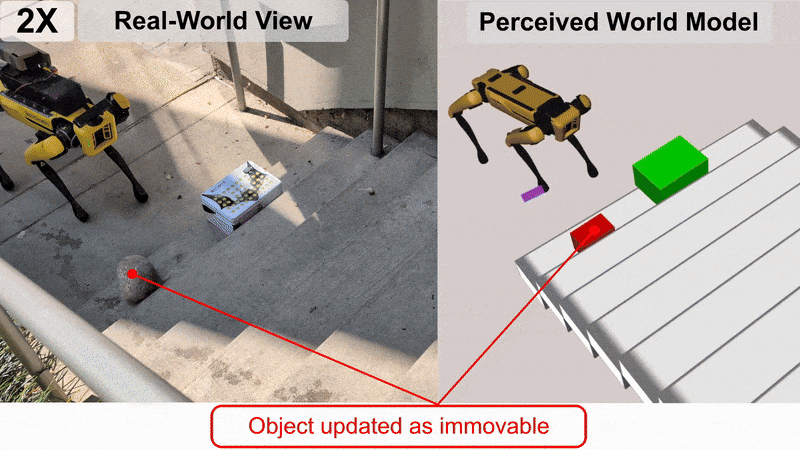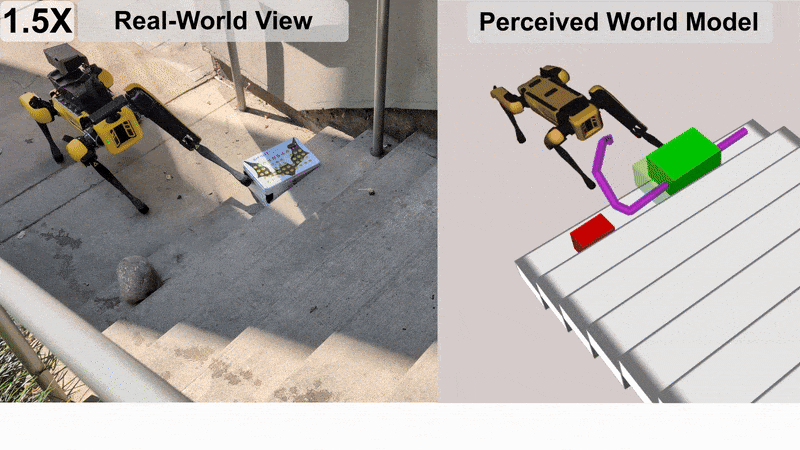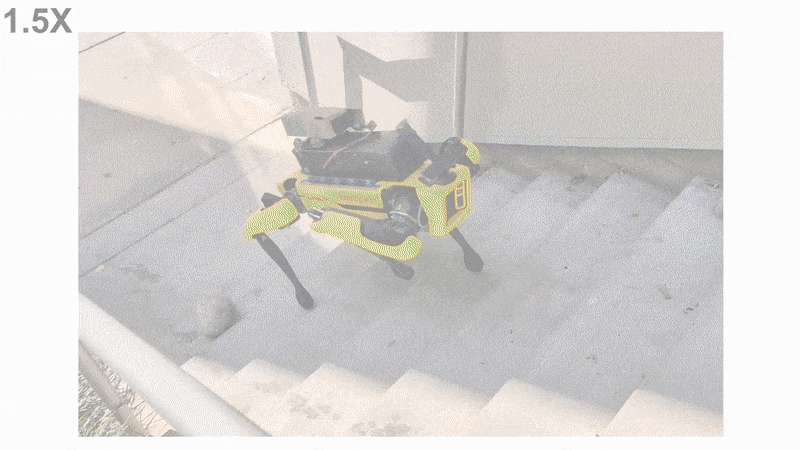
September 15, 2025Demonstrated our quadrupedal pedipulation and clutter clearing system live at the DARPA TIAMAT PI Meeting at University of Maryland, College Park
-
August 14, 2025The Matt Lab team won the Best Academic/Research Institute Technology Demonstration Award at GVSETS 2025 for our heterogeneous multi-robot collaborative autonomy stack!
-
March 10, 2025Our paper “A Bayesian Modeling Framework for Estimation and Ground Segmentation of Cluttered Staircases” is accepted to IEEE Robotics and Automation Letters (RA-L)!
-
August 28, 2023Started as a Ph.D. student at the Robotics Institute, Carnegie Mellon University, advised by Dr. Matthew Travers.
-
January 30, 2023
-
August 23, 2021Started my Master of Science in Robotics (MSR) program at Carnegie Mellon University.
You can checkout my work using these links:
Publications Projects